harmonic convergence

[rev_slider alias="adaptive-robotic-construction-1"][/rev_slider] Two KUKA industrial robots and a professional harpist share the stage, and, in part, an instrument. In this human-robot collaboration, harpist Christoph Bielefeld performs live on his own harp while the two robots play a second harp alongside him, their hard, angular mechanics set

0

Adaptive Robotic Construction

[rev_slider alias="adaptive-robotic-construction"][/rev_slider] This project, developed for the Neura Robotics Challenge, explores how autonomous mobile robots can adaptively locate, pick, and place construction-scale construction elements in response to live spatial conditions. The system integrates a holonomic mobile platform, a seven-axis collaborative robot arm, an industrial structured-light 3D scanner, and a

0

Fashion and Robotics – KUKA Innovation Award

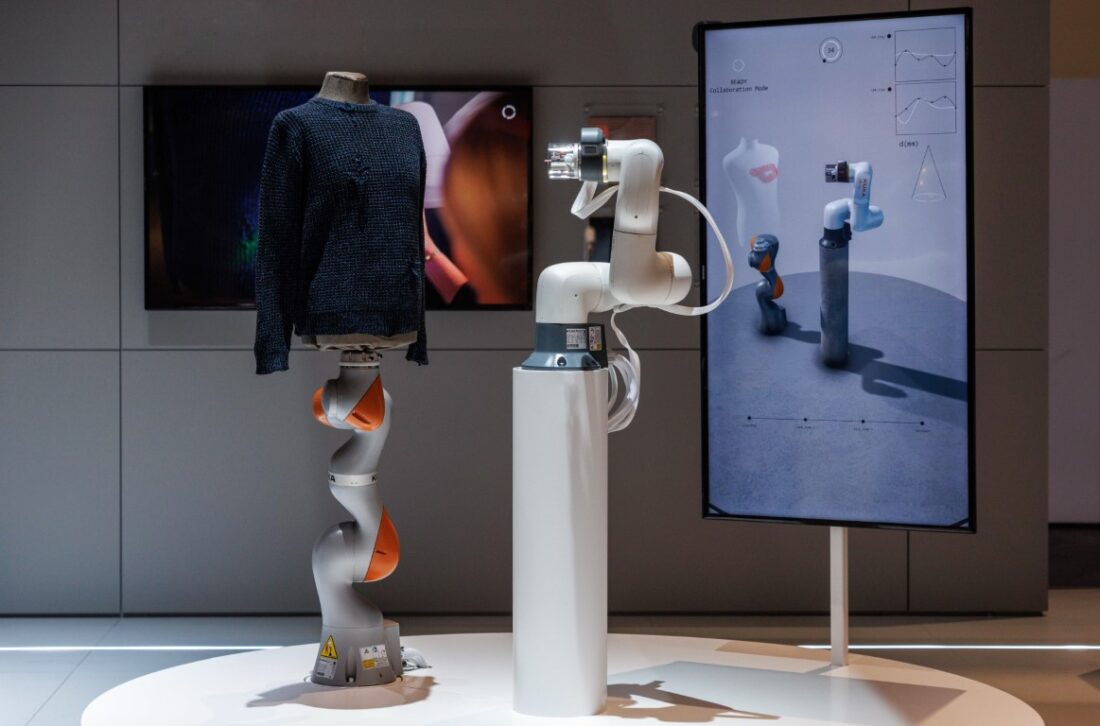
[rev_slider alias="fashion-and-robotics"][/rev_slider] This project emerged from our shared interest in sustainability, human-robot collaboration, and the intersection of creative robotics with textile futures. We explored how collaborative robots, enhanced through real-time visualisation and intuitive interfaces, can make complex remanufacturing tasks accessible to non-experts, especially within the realm

0

disarming II performance

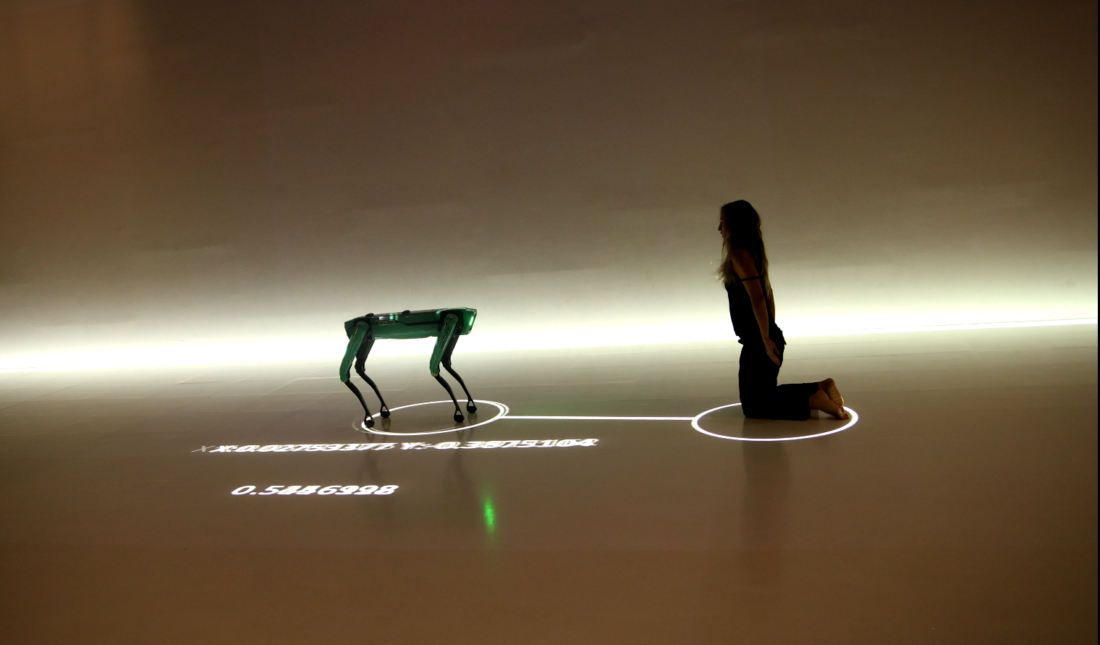
[rev_slider alias="disarming-II-performance"][/rev_slider] disarming II performance continues Emanuel Gollob´s disarming series with a performative improvisational setting involving a dancer and a detached robotic arm. Throughout the 25-minute-long performance, the detached industrial robotic arm ReBel continuously tries to learn how to move forward from the status quo in the human-robot-environment relation based

0

Vanishing Mediator

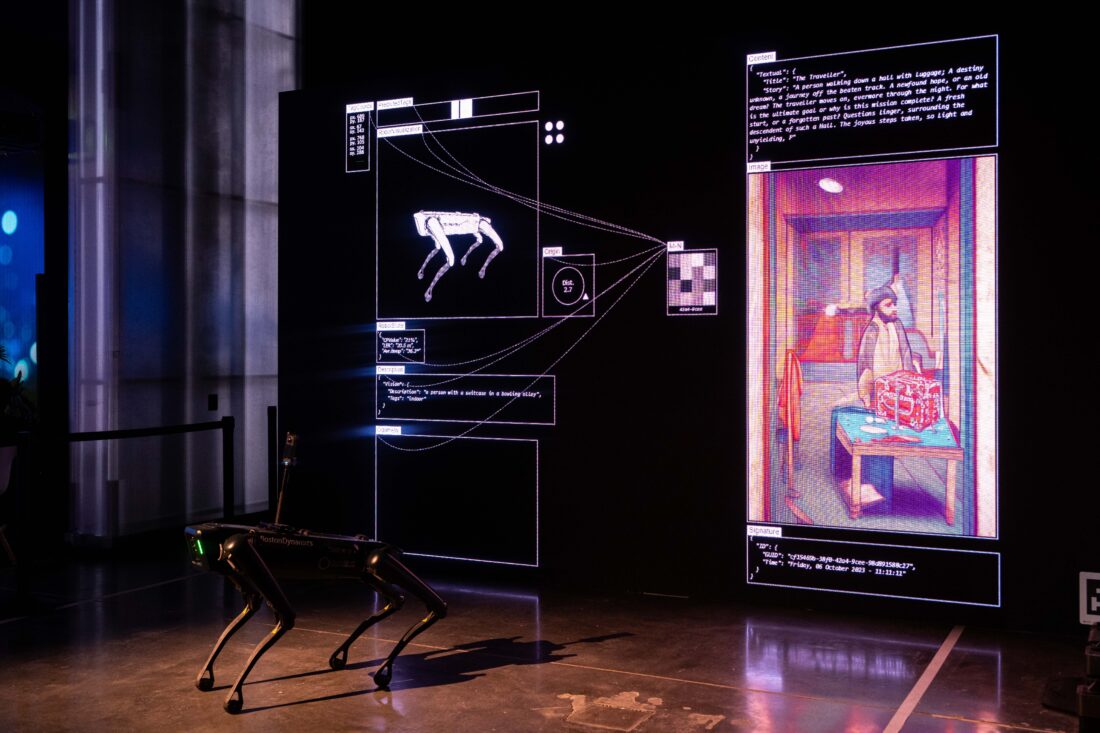
[rev_slider alias="vanishing-mediator"][/rev_slider] A robotic system blends two distinct ideas to create a visual narrative, analyzing its surroundings and using the data to generate prompts in real-time through three AI engines. This process questions the authenticity of creativity and the innovation of novelty!The concept of the Vanishing

0

ZOE

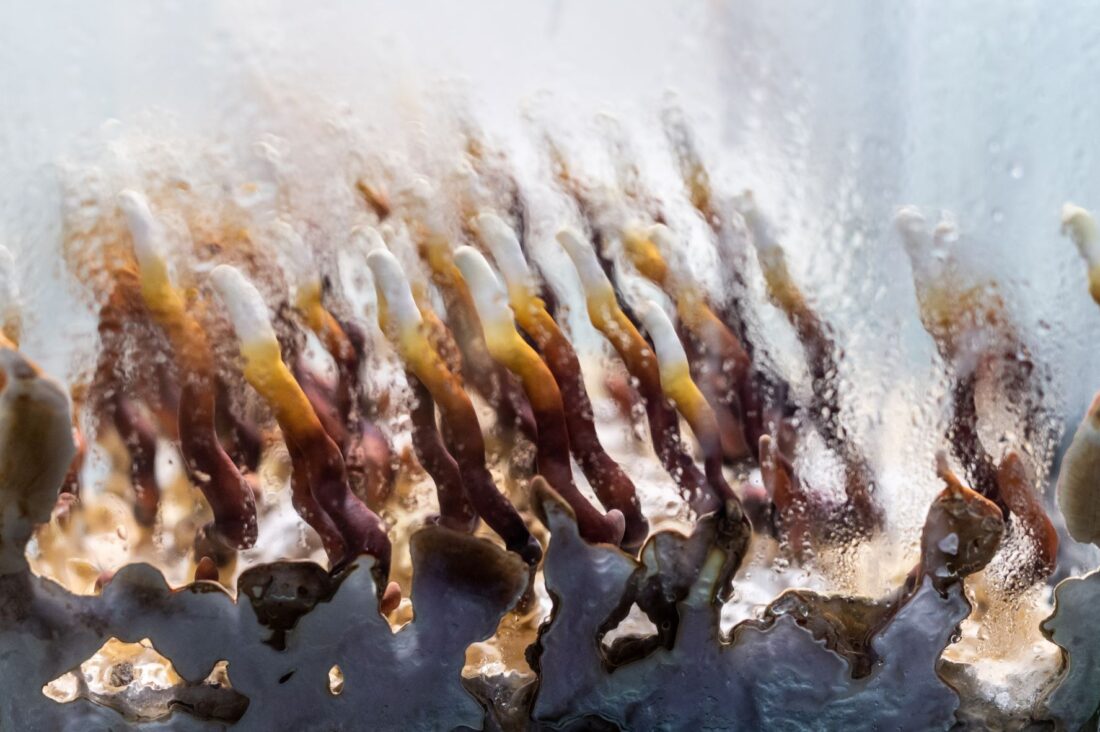
[rev_slider alias="ZOE"][/rev_slider] ZOE is a temporary co-existence between reishi mushrooms and a custom-made robotic system. Noor Stenfert Kroese and Amir Bastan explore the possibilities of internal communication between a robotic system and reishi with ZOE. Within this seeming paradox between nature and technology, an ecosystem occurs

0

ZIEN

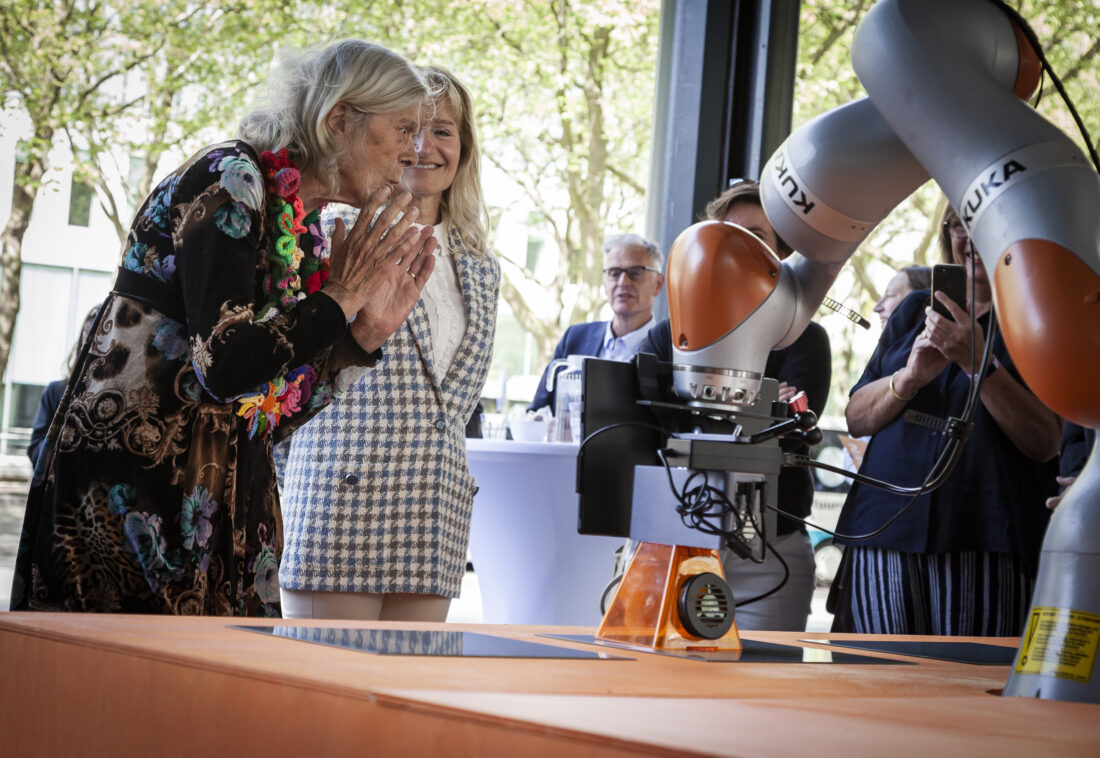
[rev_slider alias="ZIEN"][/rev_slider] ZIEN' is a participatory art project created in the spring of 2022, a light installation in front of the Dutch Ministry of Finance- Den Haag. 'ZIEN' is created in five days from the cooperation between the robot arm KUKA LBR IIWA and humans. The

0

LORMBOT

[rev_slider alias="lormbot"][/rev_slider] "Lormen" is a communication technique used by deafblind people with non-deafblind people and by deafblind people with each other. The "speaker" touches the palm of the hand of the "reader". Each finger, as well as certain parts of the hand, are assigned to specific

0

MicroVenus

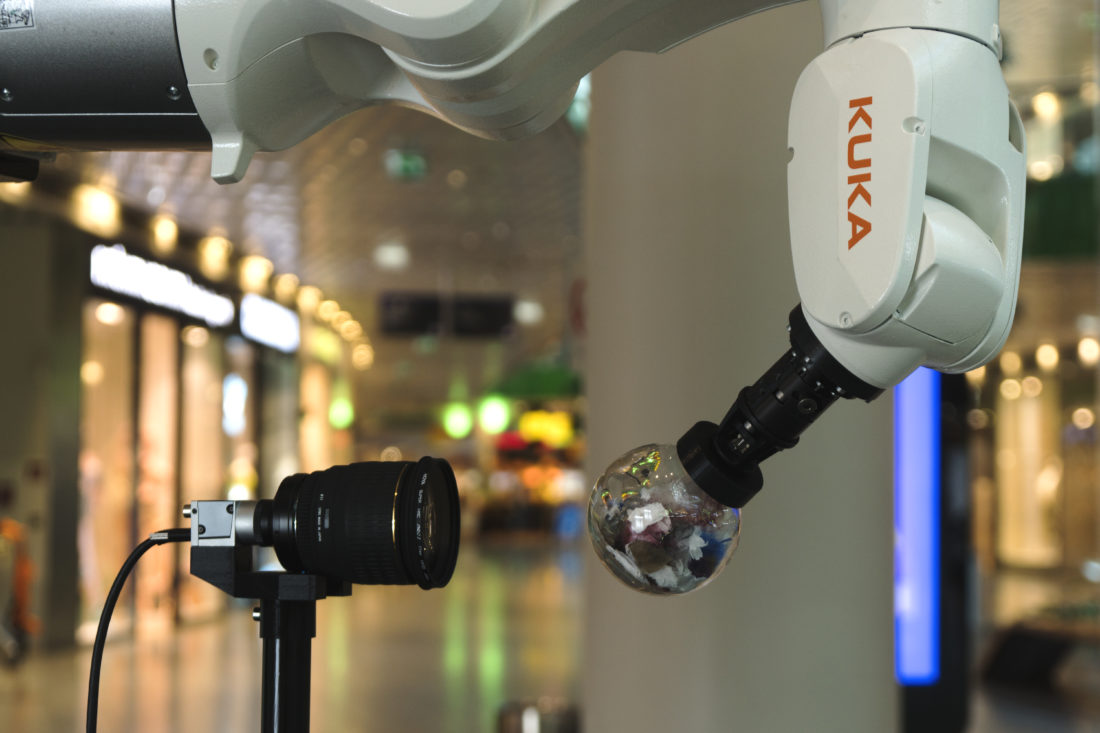
[rev_slider alias="spot-silk-1"][/rev_slider] A robotic arm is programmed to move a USB microscope with a super slow speed above an abstract-textured object while a high-resolution screen shows the moving image of the microscope in real-time. The microscopic landscapes appear bigger than the object itself. Through a touchless interaction process

0

SPLIT SUBJECT

[rev_slider alias="pavilion-11"][/rev_slider] a Lacanian term in the notion of the Subject in Psychoanalisys. It is also known as "$" in Lacan's four forms of discourse. Now, what if the interaction under the hood of Human Robot Interaction or HCI in general is rather the opposite? Perhaps it is first

0